Capturing Moving object using onboard sensoring
Science Robotics, 2024
This represents the fastest and most accurate vision-based grasping performance reported in the literature.
I am a Ph.D. student at the School of Automation Science and Electrical Engineering and Shenyuan Honors College, Beihang University, China. I am supervised by Prof. Lei Guo, Prof. Xiang Yu, and Prof. Kexin Guo. Robots deployed in the real world inevitably face uncertainties caused by internal model mismatch and external unmeasured disturbances. The topic of my Ph.D. research is intelligent control and dexterous operation of aerial manipulator.
This represents the fastest and most accurate vision-based grasping performance reported in the literature.
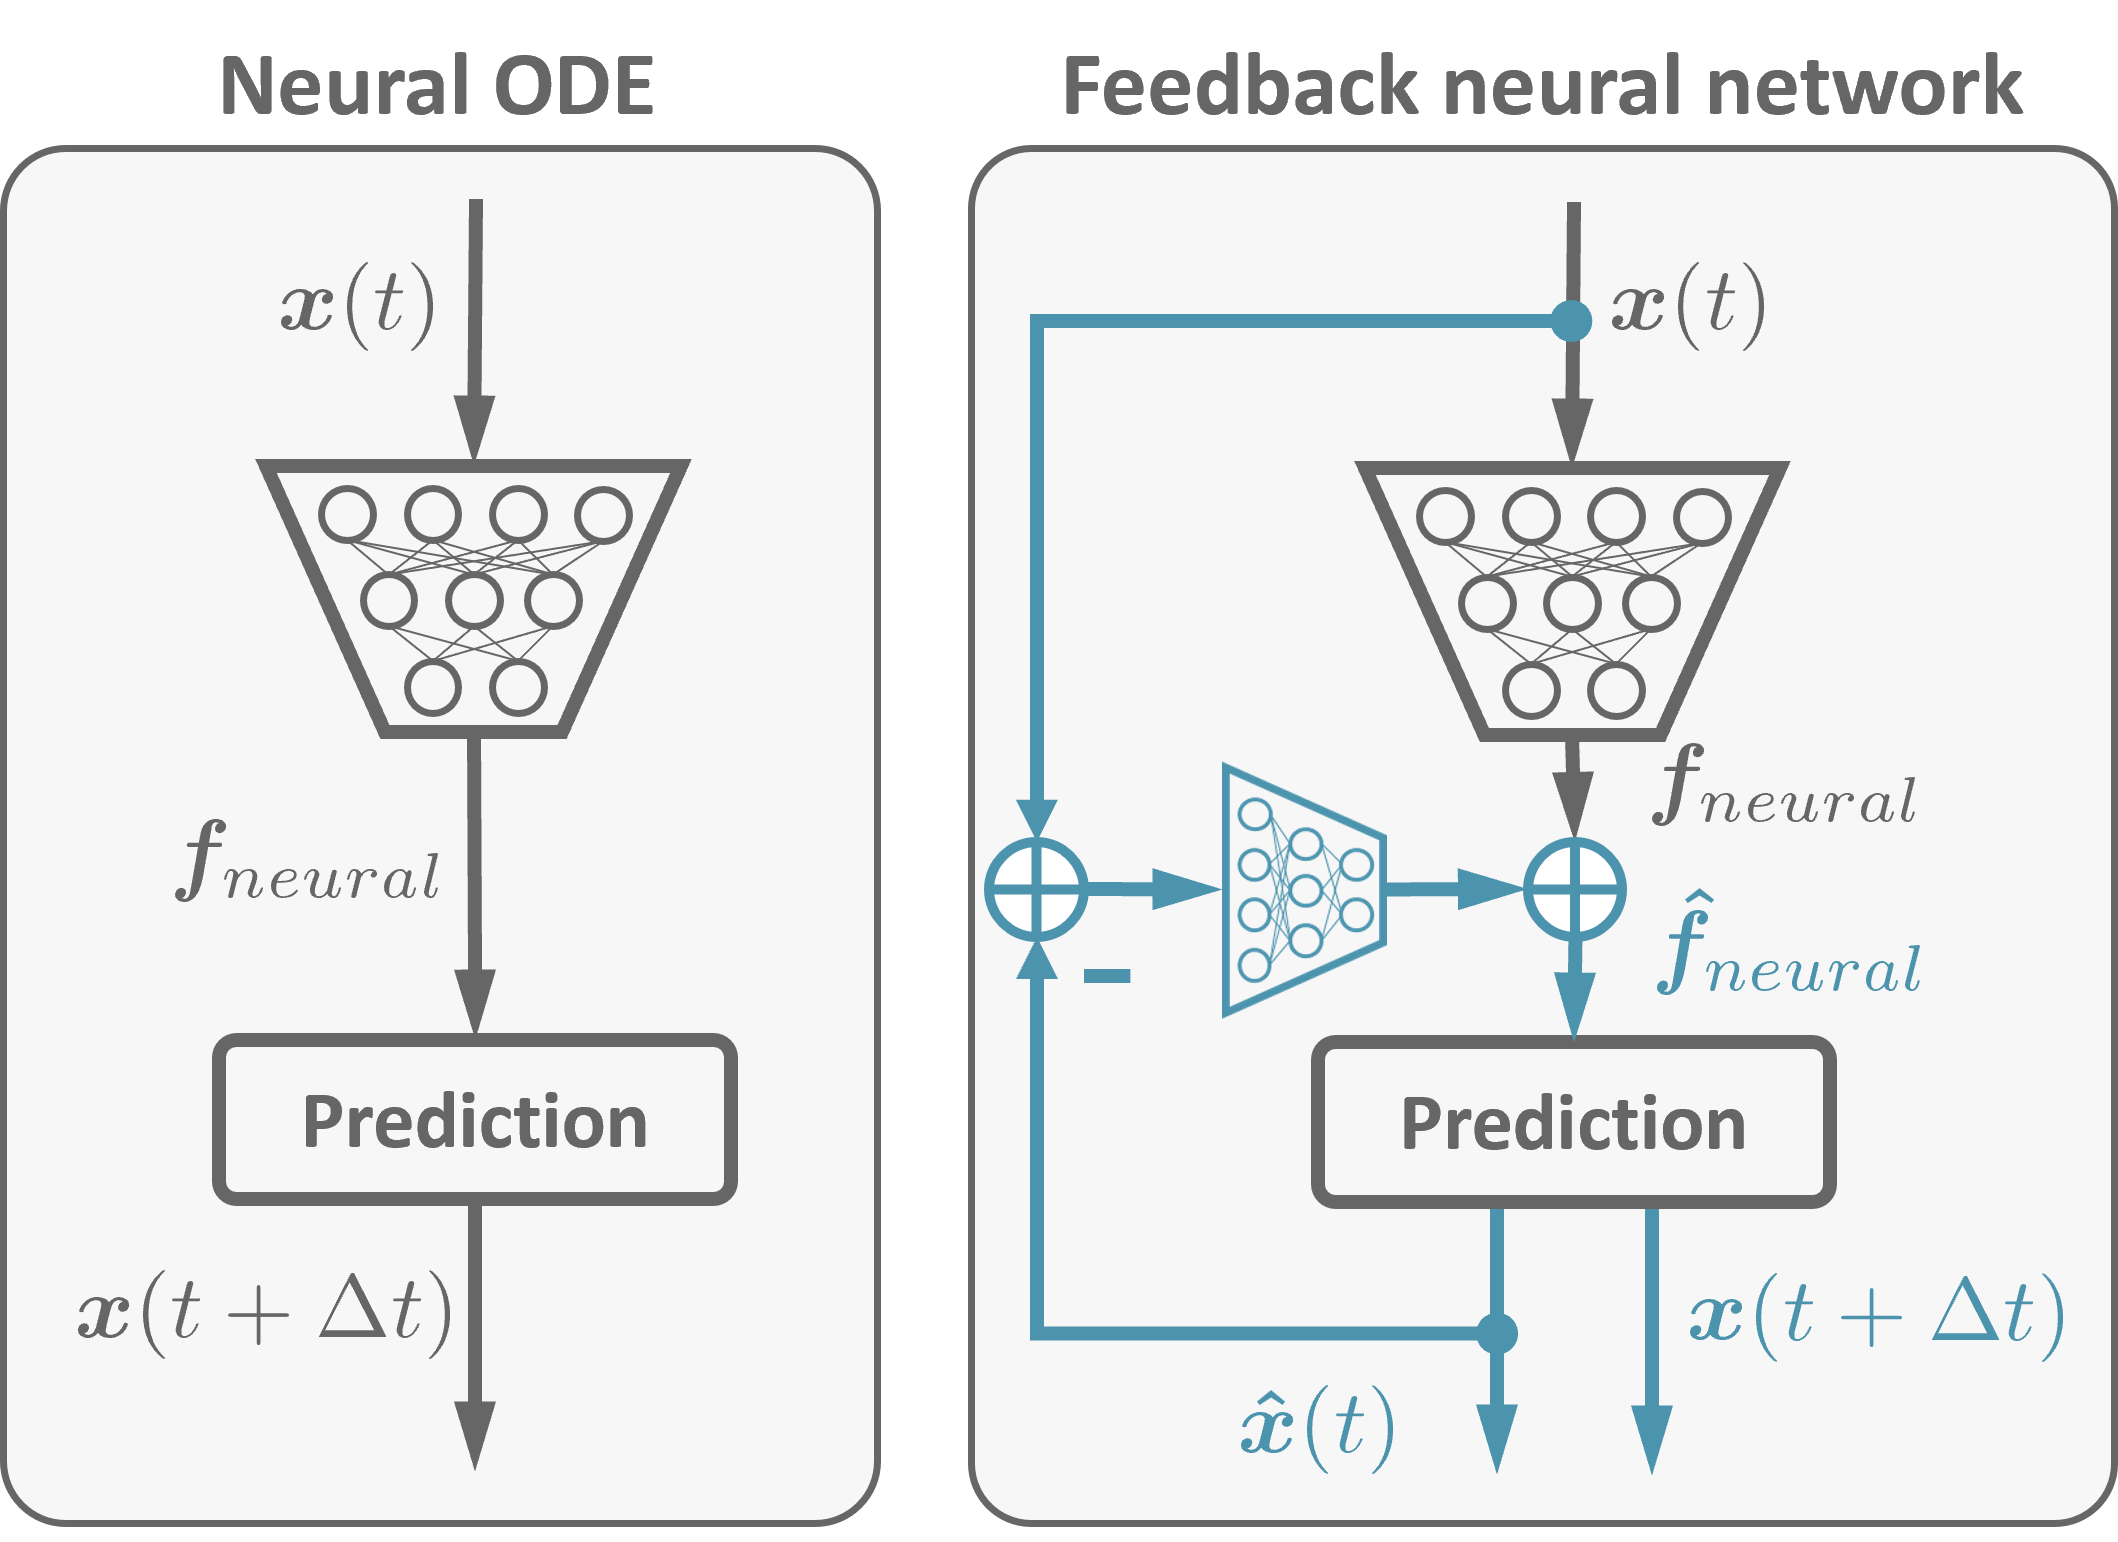
We present feedback neural networks, showing that a feedback loop can flexibly correct the learned latent dynamics of neural ordinary differential equations (neural ODEs), leading to a prominent generalization improvement.
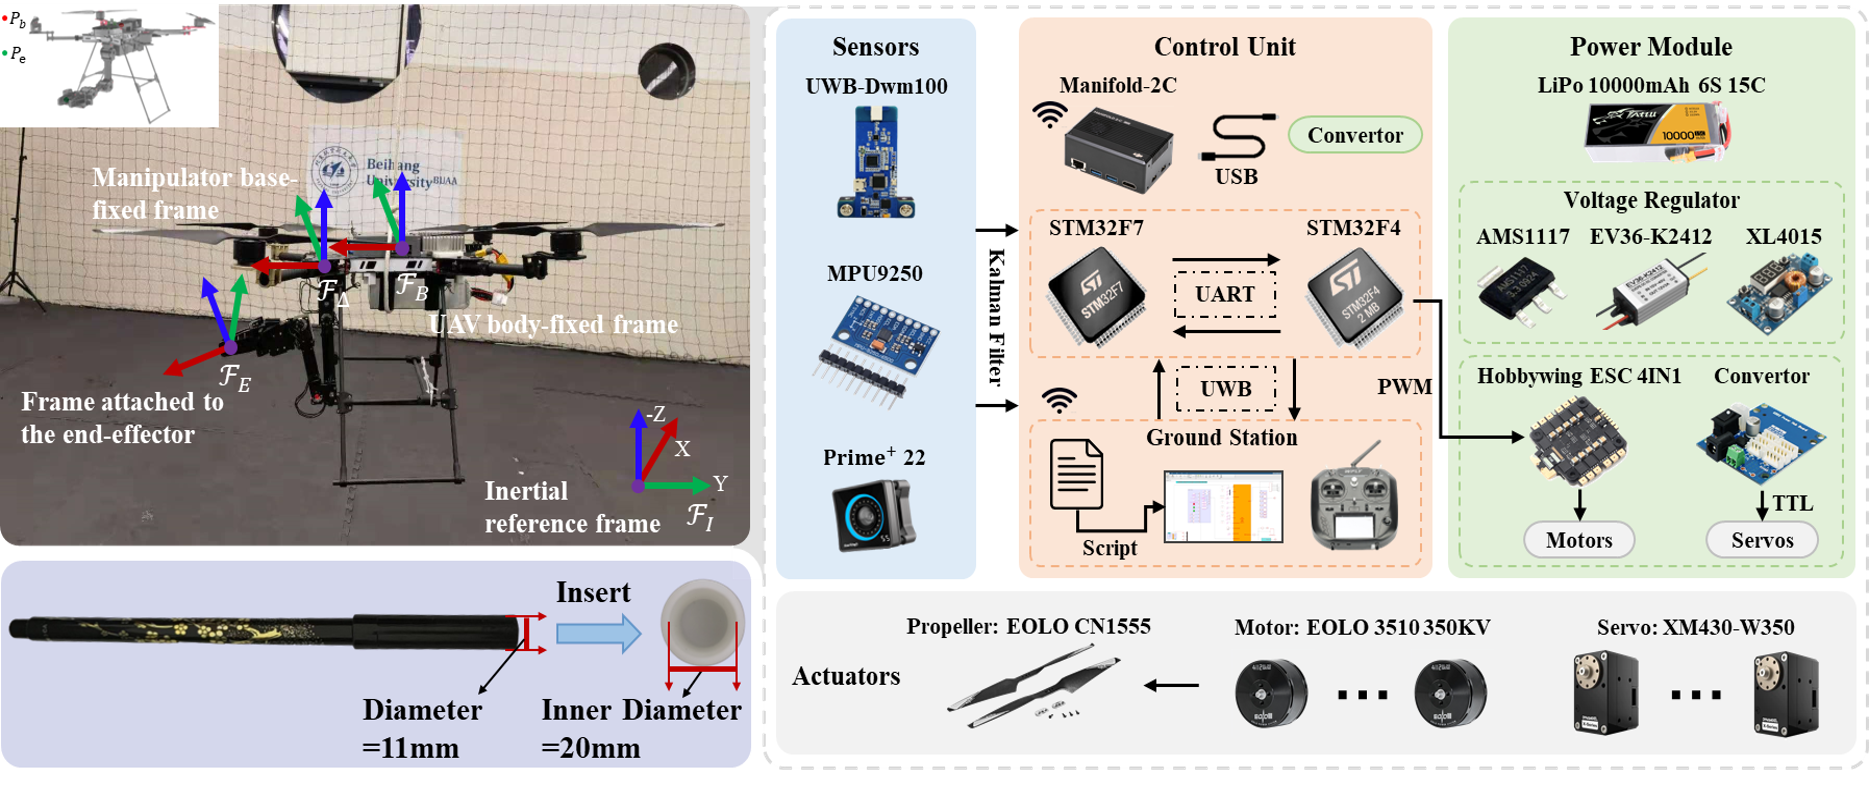
Building upon the philosophy of disturbance rejection, we propose a predictive optimization scheme that allows aerial manipulator to successfully execute millimeter-level flying pick and peg-in-hole task.

In this work, a composite control scheme is constructed, which consists of the manipulator joint velocity planner and the dynamic controller. The idea is intuitive. The joint velocity is generated to counteract the fluctuation of the aerial platform. Furthermore, the dynamic controller is developed to accurately track the planned joint velocity in the presence of strong coupling and model uncertainties. The proposed scheme guarantees the stability of the close loop system, making our approach especially promising solution for aerial manipulation under composite disturbances.